Projects
Academic and applied engineering projects in robotics, automation, and control systems.
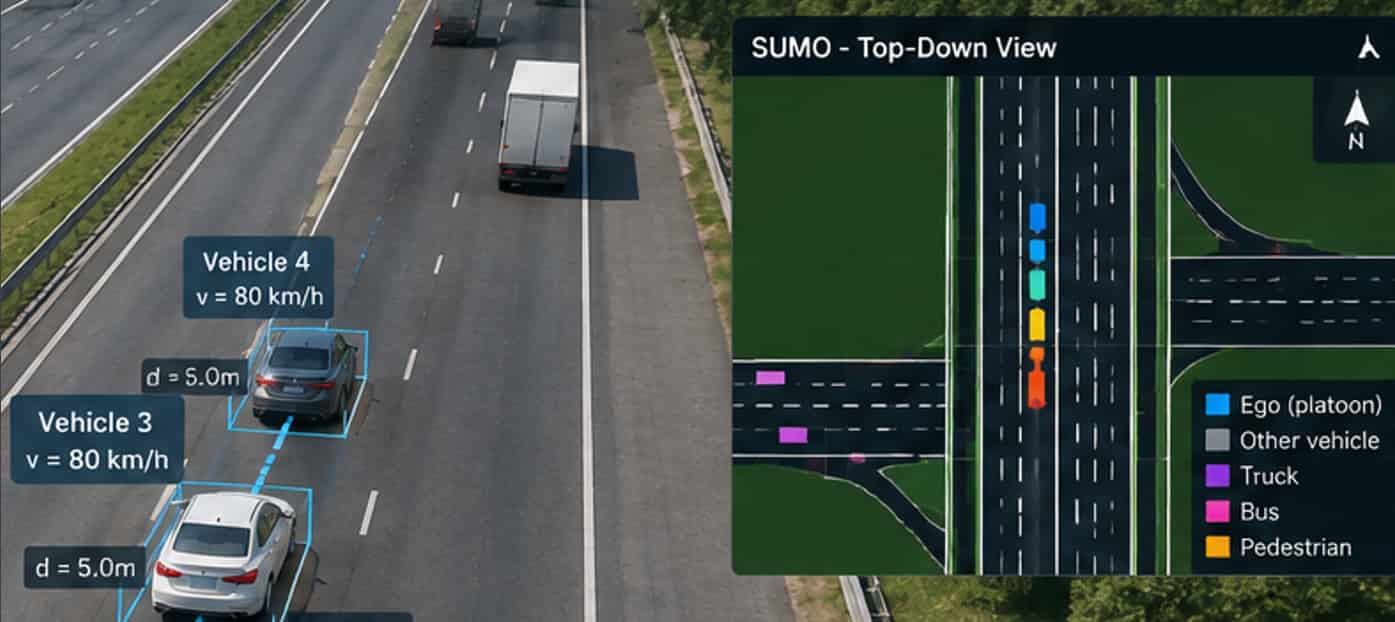
Hybrid Data-Model-Knowledge Architecture for Platooning (Bachelor Thesis)
Design and verification of a multi-layer supervisor control architecture combining Reinforcement Learning safety filtering and High-Fidelity Digital Twin dynamics.
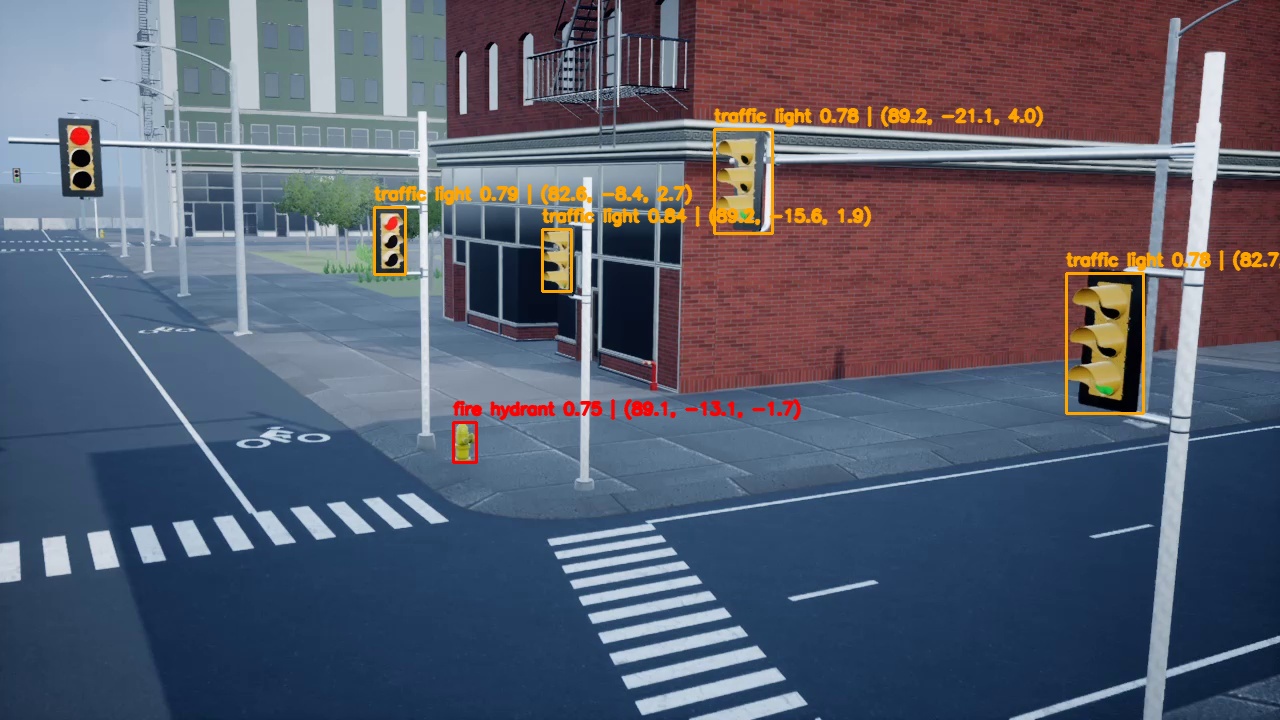
LiDAR-Based Localization & Environment Recognition for an Autonomous Aerial Vehicle
Development of a multi-sensor localization and environment recognition pipeline for a simulated aerial vehicle, integrating LiDAR, camera, and IMU data for 6-DoF pose estimation, trajectory evaluation, and 3D object localization.
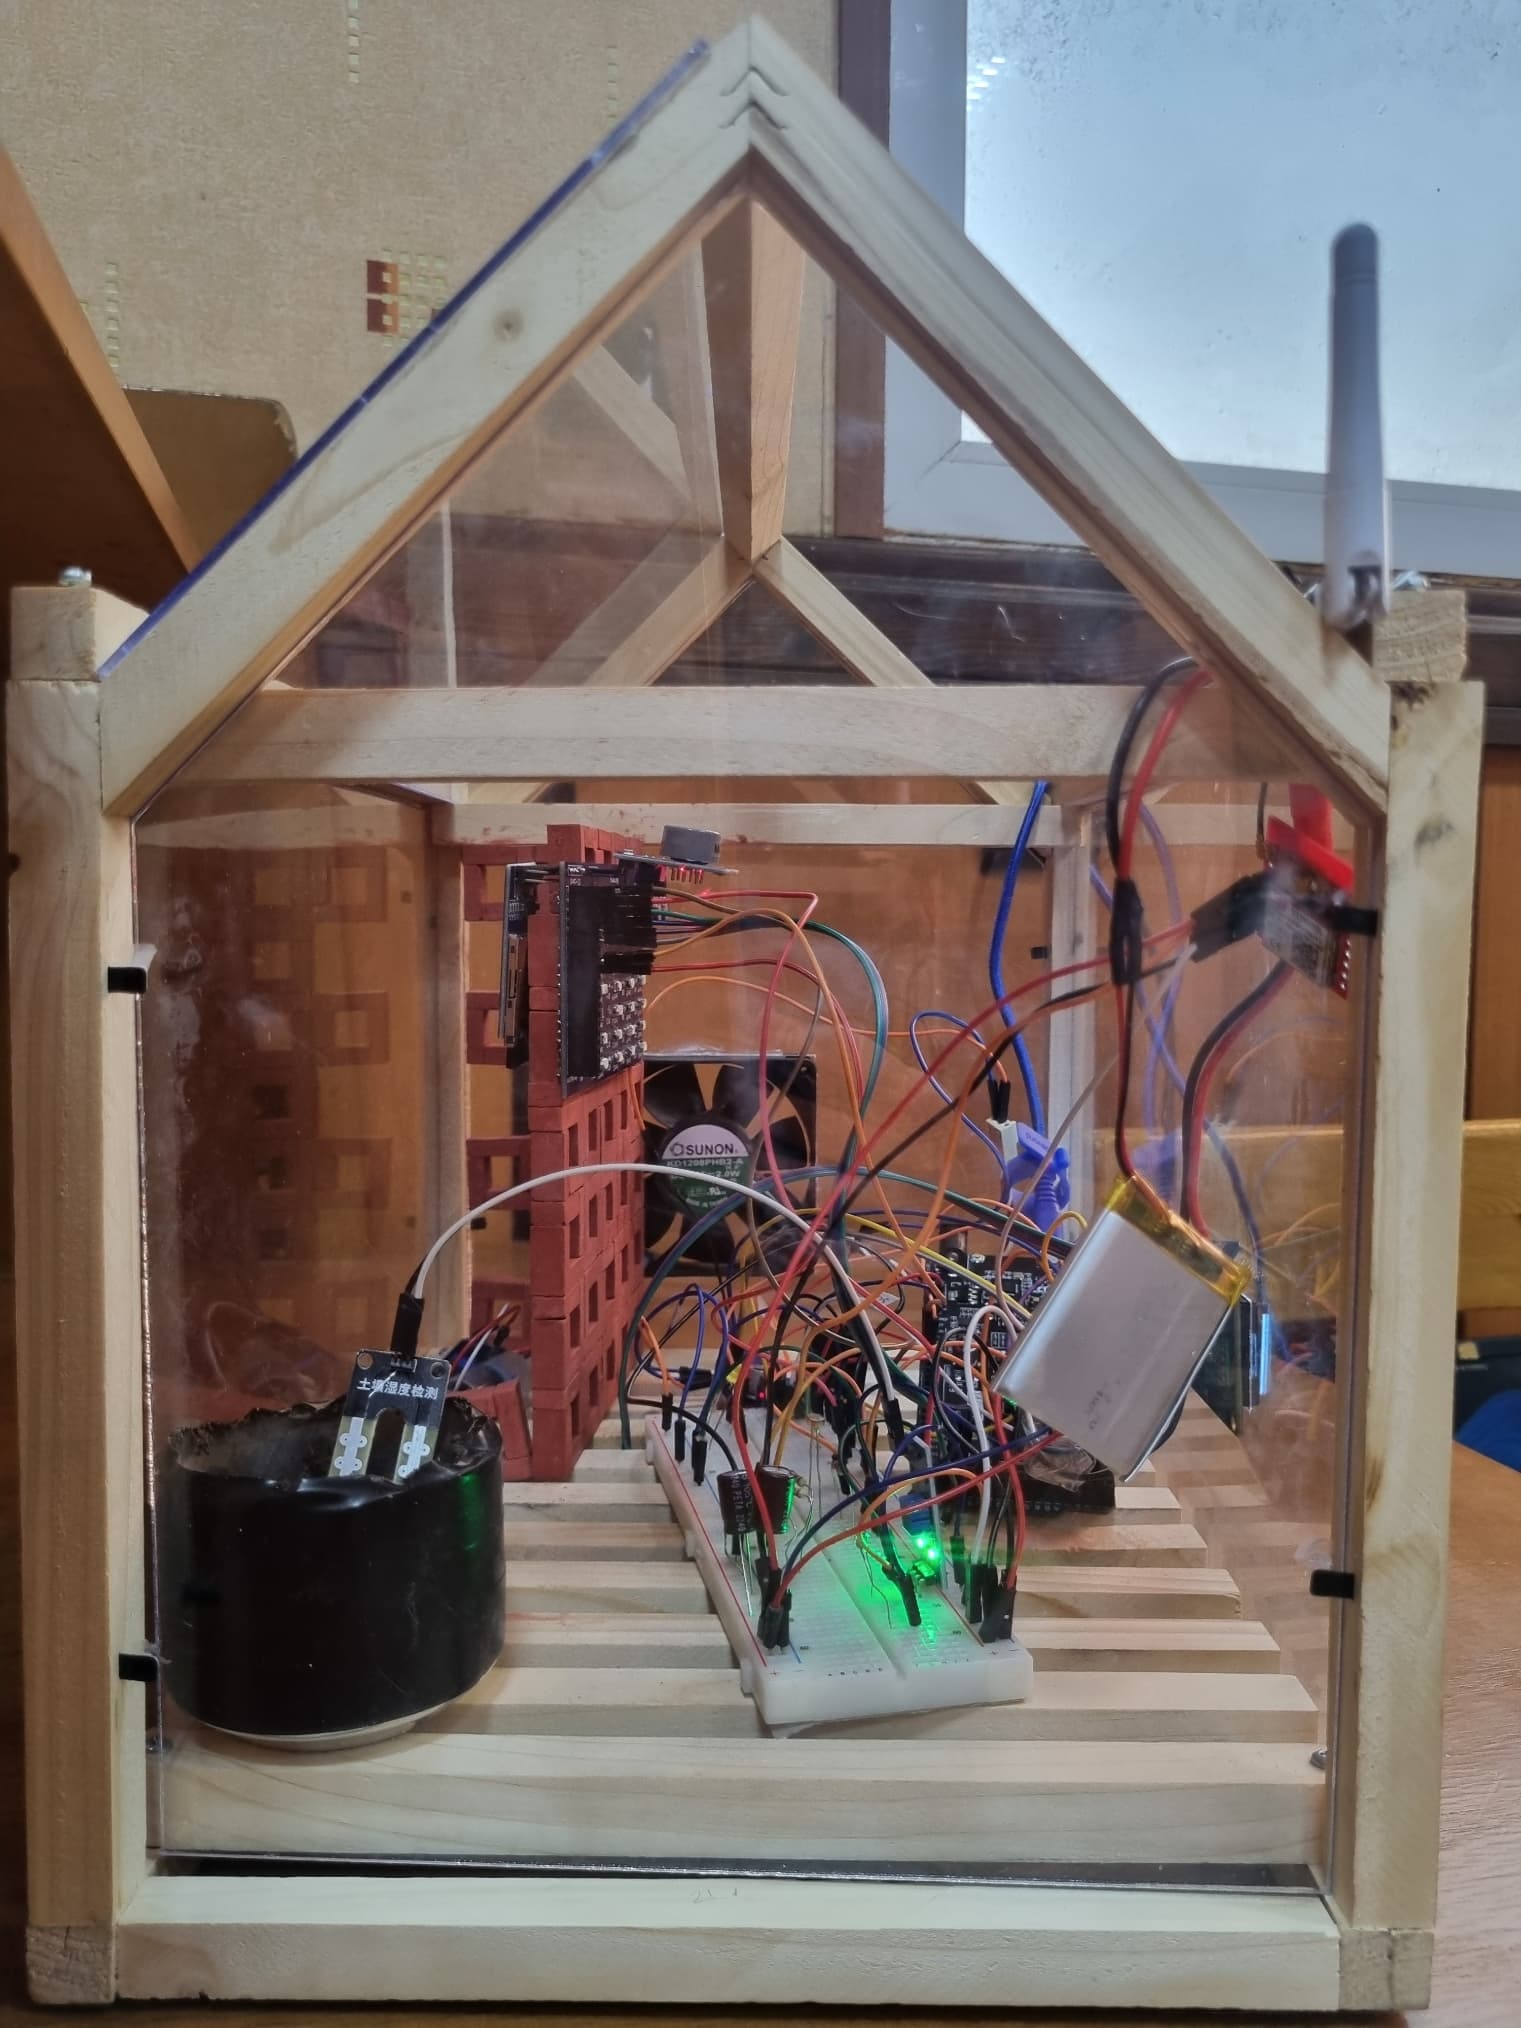
Green House Automation System
An automated greenhouse environmental monitoring and control system utilizing distributed sensors, actuators, and an embedded control unit.
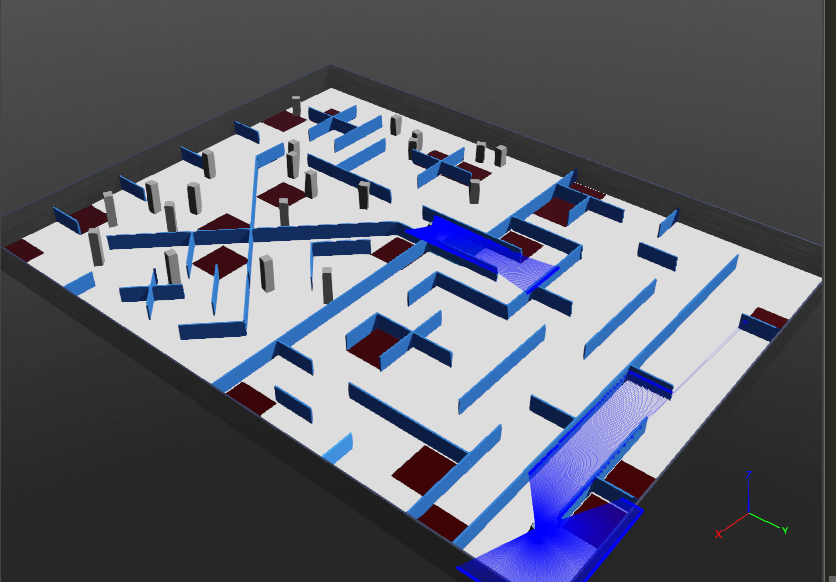
Collaborative Maze Navigation with e-puck Robots
Implementation and evaluation of a two-dimensional Simultaneous Localization and Mapping algorithm for differential drive robots within Webots simulator.
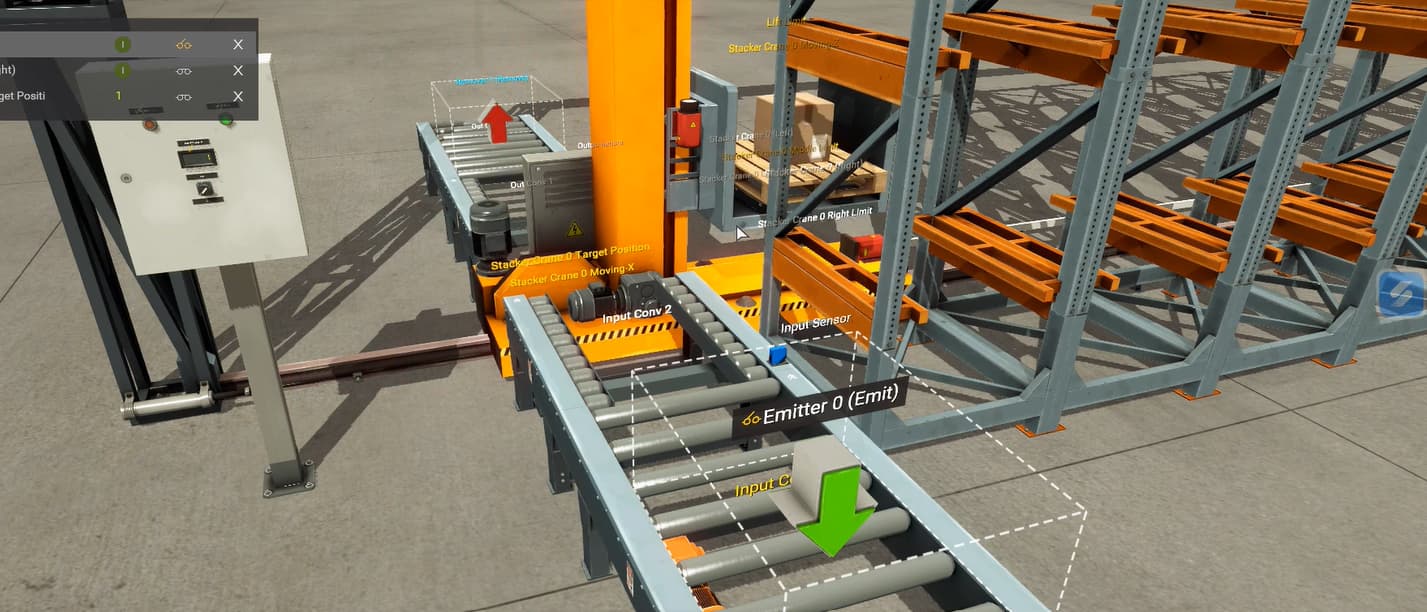
PLC Systems and Control Projects
Design and implementation of industrial automation loops, safety logic, and sequential processes across various PLC controllers.
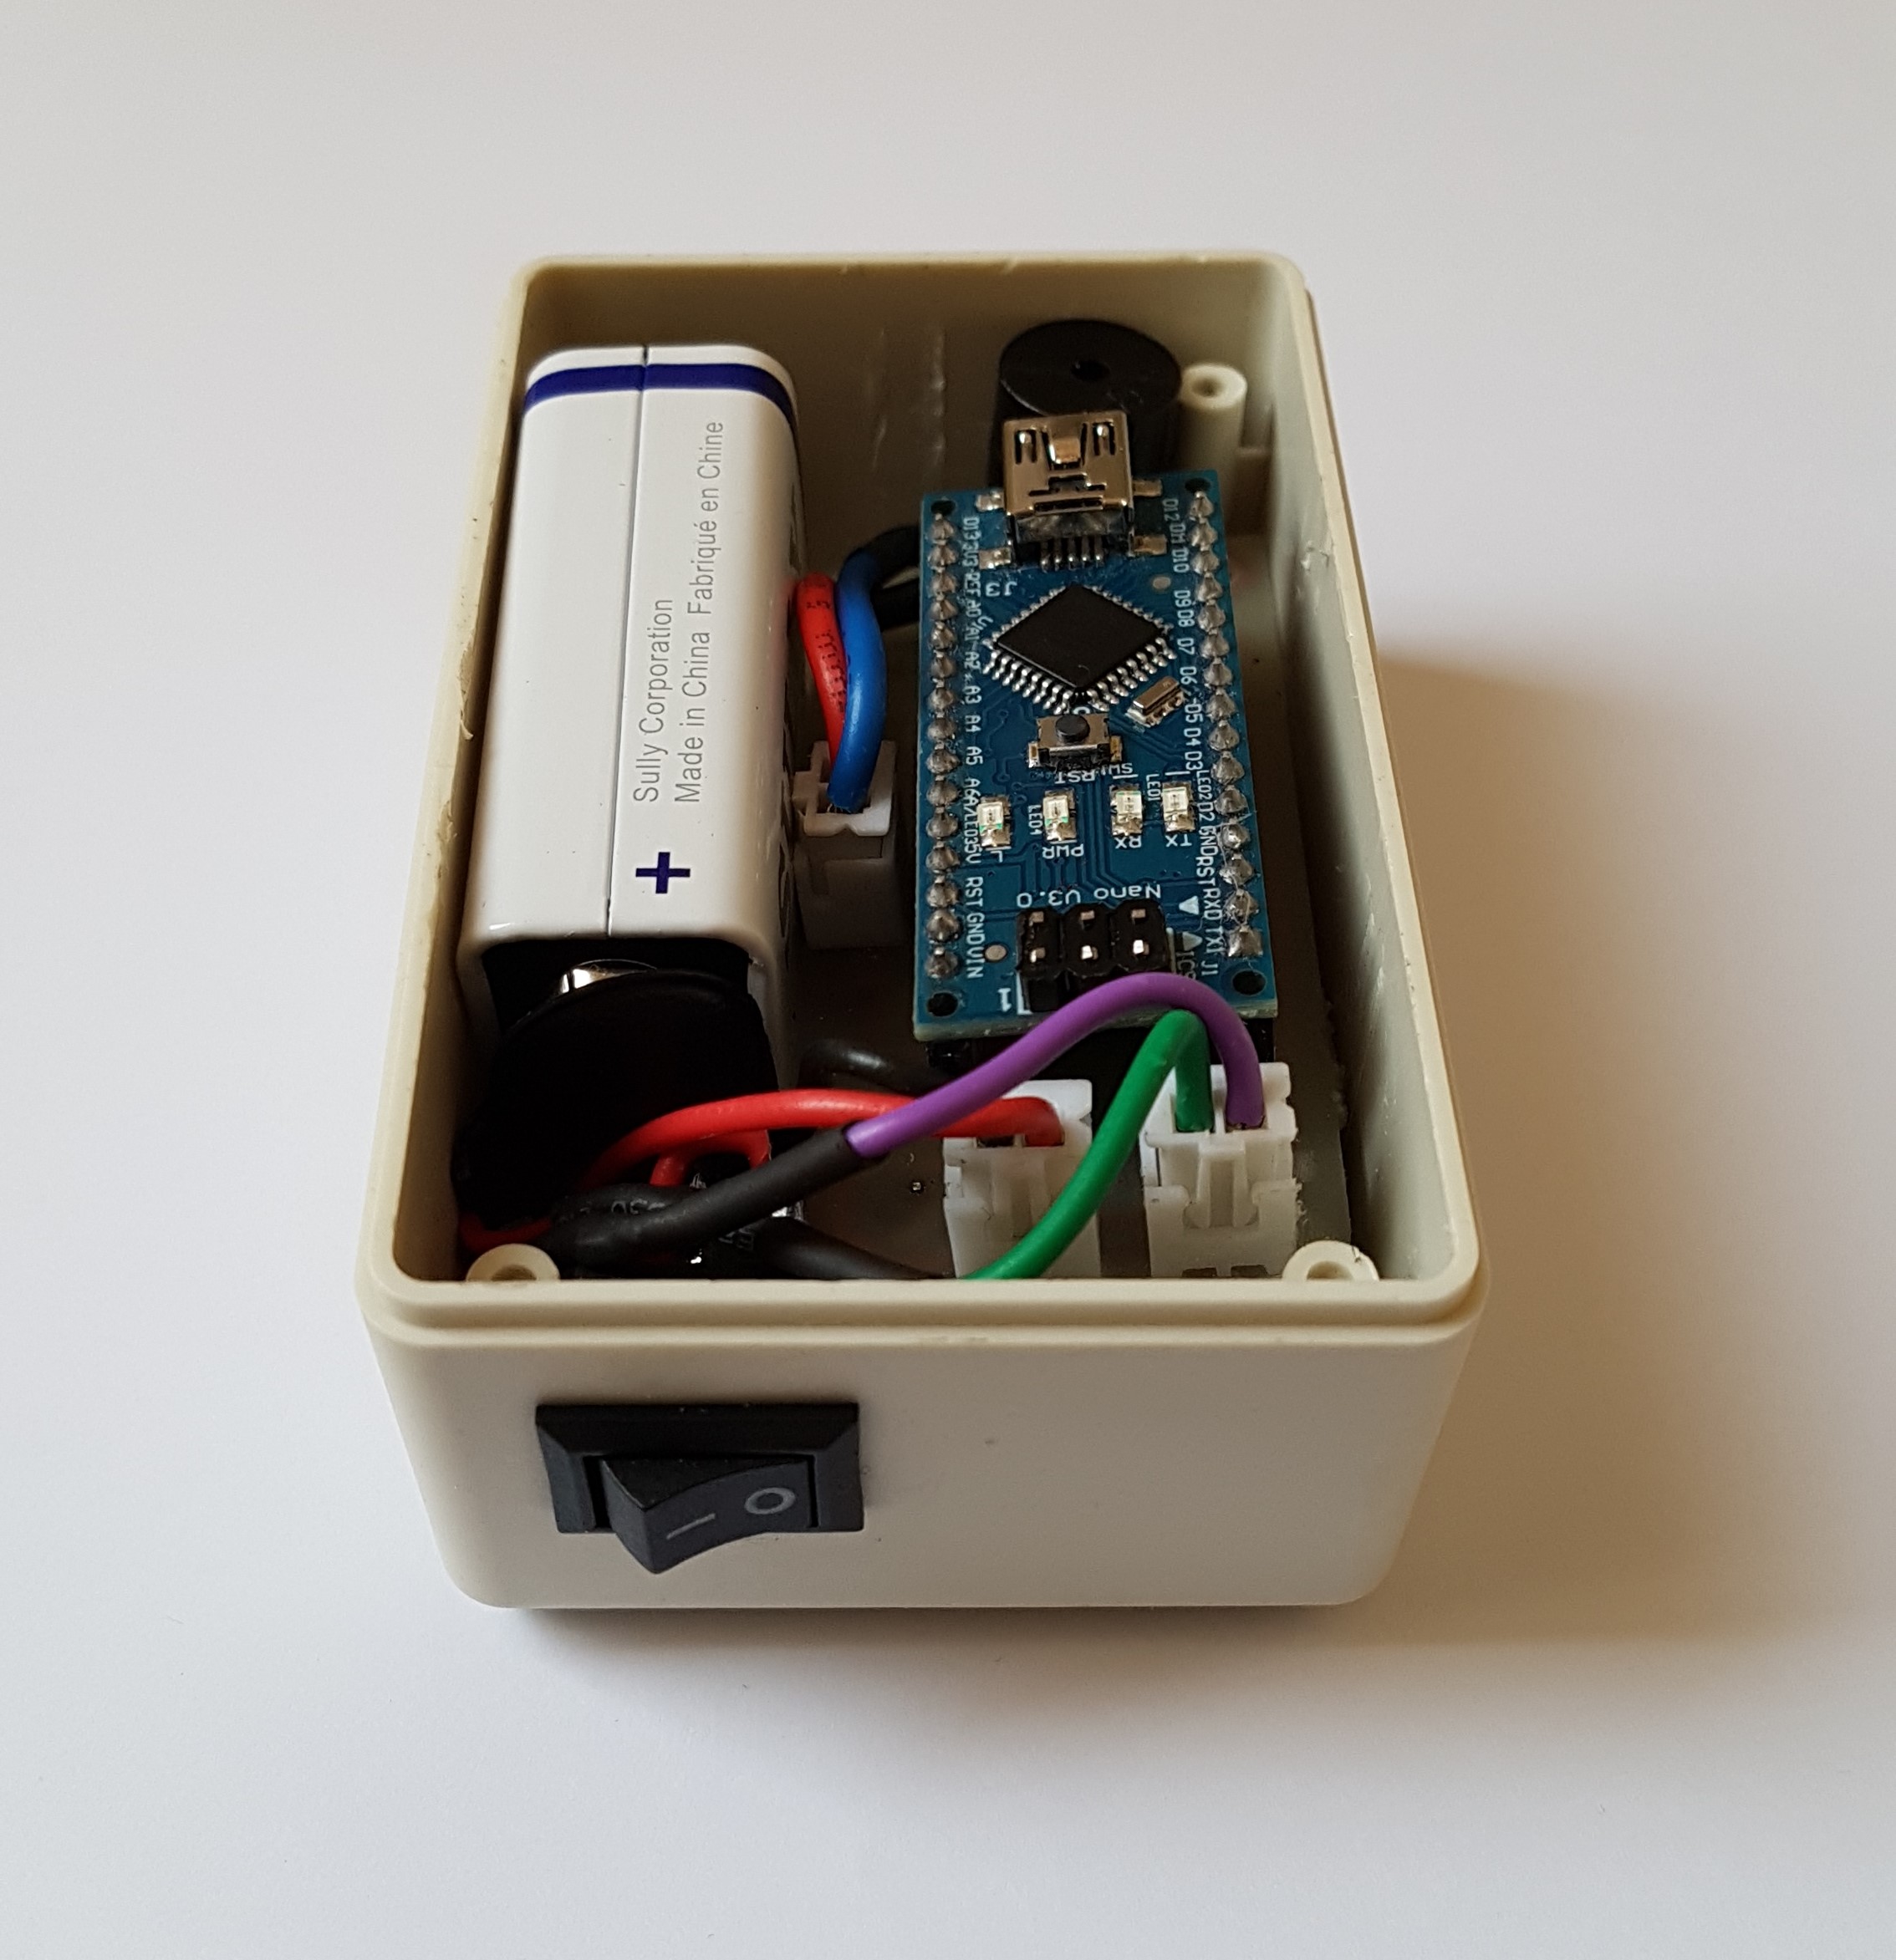
Sports Performance Analysis Device
Hardware prototype and signal processing pipelines using IMU sensors to track, classify, and analyze physical motions and athletic performance metrics.